Research
Our mission is to enable the widespread use of intelligent robots to serve society, by enabling them to better understand their environment and react optimally to a variety of situations.
Our research covers several key areas:
- Inspection and Maintenance: Improving the sustainability of critical infrastructures through monitoring missions on power lines, dams and aeronautical structures.
- Safety and Surveillance: Contributing to search and rescue missions, driver assistance, space exploration, and monitoring of events such as forest fires, floods and avalanches.
- Conservation: Ensuring the preservation of ecosystems by monitoring endangered and invasive species, as well as mapping forests, seabeds and glaciers.
Future projects
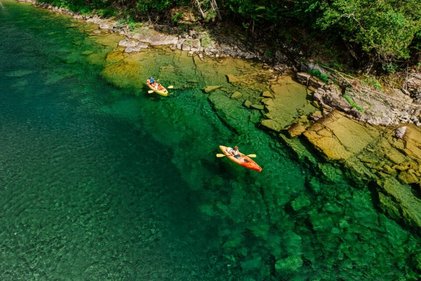
Automated detection of salmon using drones and underwater cameras
GNSS-denied navigation for aerial robots
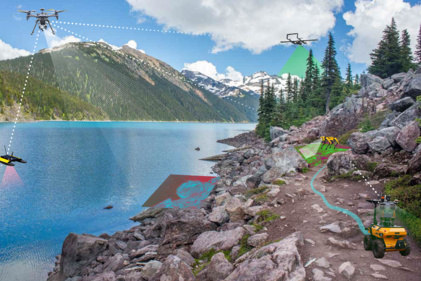
Active mapping for heterogeneous multi-robot systems
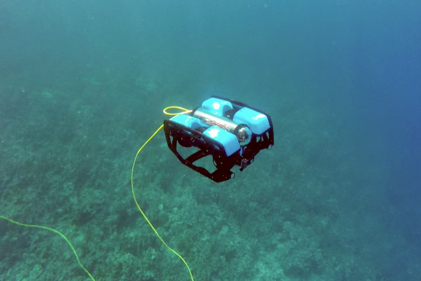
Infrastructure inspection with autonomous underwater robots

Mapping plants in Canadian lakes using autonomous aquatic robots
Ongoing Projects

Image recognition for the inventory of endangered plants using UAVs

Off-road autonomous driving and advanced driver-assistance systems
Completed Research Projects

ARENA: Adaptive Risk-aware and Energy-efficient NAvigation for Multi-Objective 3D Infrastructure Inspection with a UAV

Topological Mapping for Traversability-aware Long-range Navigation in Off-road Terrain

Active Sampling, Modeling and Estimation in Aquatic Environments

MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV

TAPE: Tether-Aware Path Planning for Autonomous Exploration of Unknown 3D Cavities using a Tangle-compatible Tethered Aerial Robot
